Robotics Researcher

Shiva Rudra
Lolla

Helping robots see, navigate, and act.

I’m Shiva Rudra, a robotics researcher passionate about robot vision and intelligent systems. My work spans building systems that help robots understand complex environments, make reliable decisions, and operate effectively in the real world across both research and applied settings.
Robot Vision & 3D PerceptionPhysical AIAutonomous Systems
My background

From research to real-world robotics.

Research

  • Student Researcher

    Humanoid Robots Lab, University of Bonn, Germany

    December 2025 - Present
  • Research Intern

    Robotics Research Center, IIIT Hyderabad, India

    June 2023 - December 2023

Industry

  • Robot Navigation Engineer

    AlphaZ, Los Angeles, California, USA

    May 2024 - September 2025

Education

  • M.S. in Mobile Robotics

    University of Bonn, Germany

    October 2025 - September 2027 (Expected)
  • B.E. in Electronics and Instrumentation

    BITS Pilani, Hyderabad, India

    November 2020 - May 2024

Publications

Research papers and workshop contributions.

Projects

Ideas brought to life through code, hardware, and experiments.
*
Vision-Guided Brick Sorting with a Franka Arm
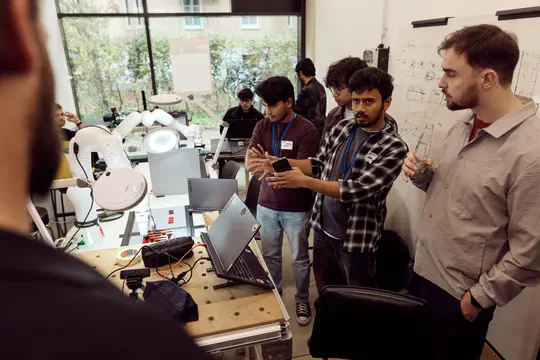
Led perception for Team KalmanKrew at the robo.innovate Hackathon 2026 (Track 08, Marmon). I designed an RGB-D pipeline that finds the reachable top layer of a brick stack with SAM 3 and depth geometry, classifies each brick by colour, and hands 3D pick targets to a Franka Research 3 for sorting.
Explore project
Vision-Guided Brick Sorting with a Franka Arm
Automated 3D Reconstruction of Buildings
Reconstructed Bonn roofs from airborne LiDAR and built a LoD3 façade prototype that uses street imagery and laser returns to recover windows and doors.
Explore project
Implementing ESDF Mapping with VINS
The ESDF map is made using pointcloud data from the depth camera and rectified odometry from the VINS framework. Voxfield framework is utilized for this purpose
Explore project
Implementing ESDF Mapping with VINS
Wheeled Biped
Designed the control system for translational and jumping motion of a wheeled biped robot. LQR controller is used for translational self balancing motion and PD-fuzzy logic controller is used for jumping motion
Explore project
Wheeled Biped
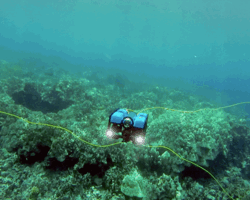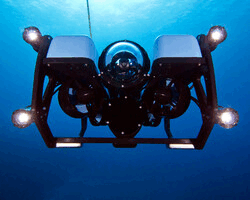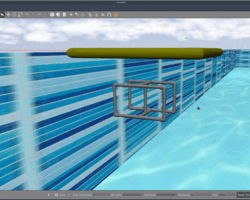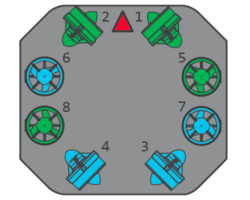
Six DOF ROV Control System Design
Designed and Simulated an underwater ROV control system using PID and LQR controllers and performed a comparative study of both the models
Explore project
Six DOF ROV Control System Design
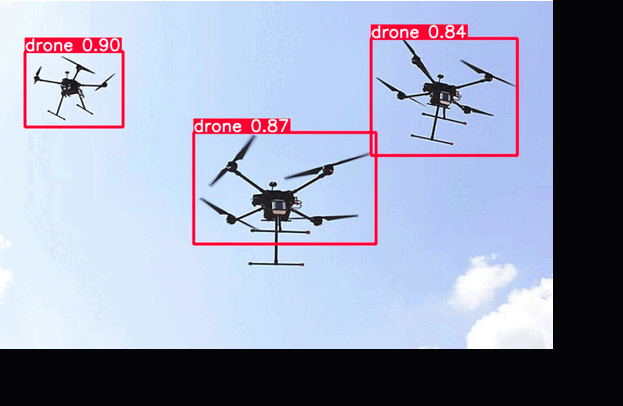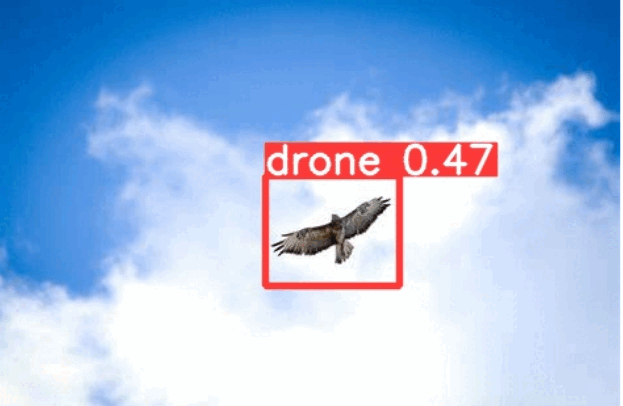
Drone Detection Using DL Methods
Implemented drone detection using Yolo algorithms and techniques like layer freezing, image augmentation. Performed comparitive study of various scenarios and test cases
Explore project
Drone Detection Using DL Methods
Robotic Arm
Design and fabrication of a Resistive touch controlled manipulator
Explore project
Robotic Arm
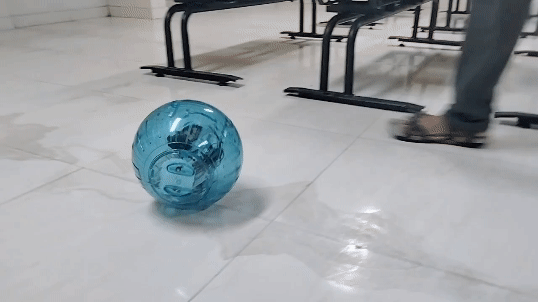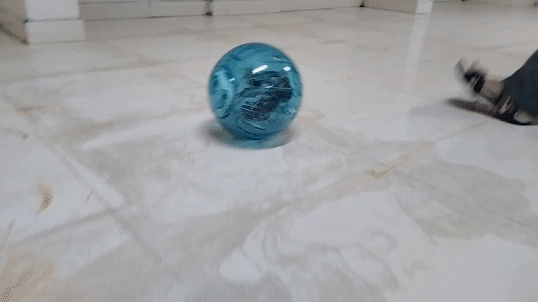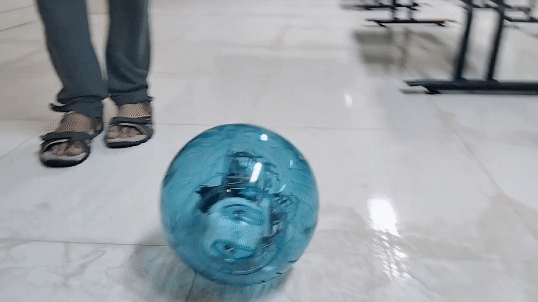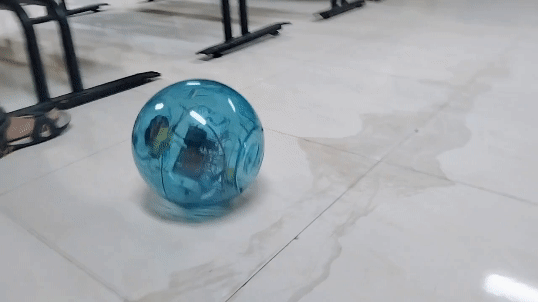
Spherical Robot
A spherical surveillance bot which can move around get a live video feed of the surroundings
Explore project
Spherical Robot

Contact

I’m always excited to connect over robotics, research, and ideas that push intelligent systems forward!